
Robot gripper: how robots hold objects
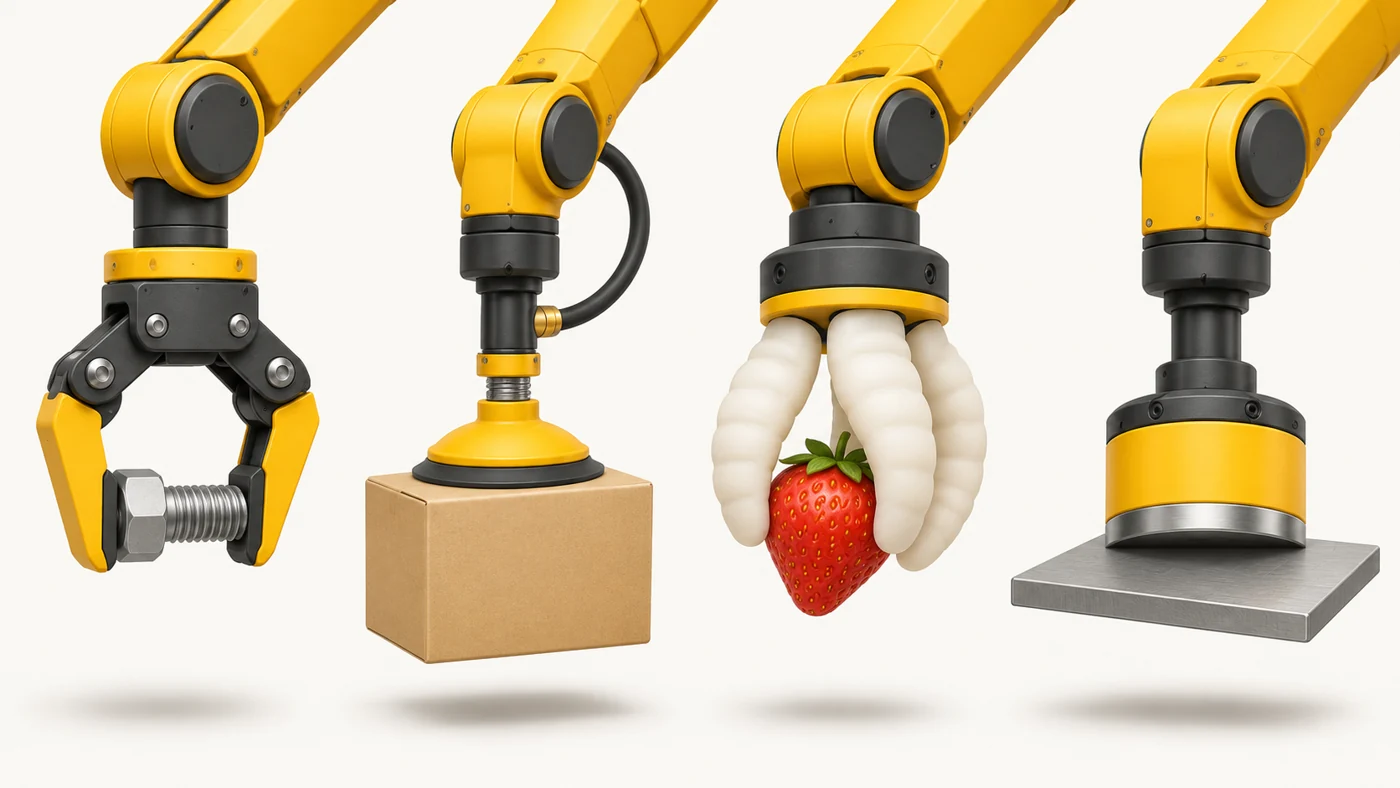
A gripper (end effector) is the device at the end of a robot's arm that it uses to pick up and hold things: mechanical "fingers", vacuum suction cups, magnets or soft silicone grippers.
In plain words
You pick up a glass, an egg and a wet bar of soap differently - your fingers choose the force on their own. A robot cannot do that "from birth". So it gets different "hands" for different jobs: a suction cup for boxes, a magnet for metal, soft silicone fingers for strawberries, precise mechanical fingers for small parts.
How it works
- The gripper is mounted at the end of the robotic arm.
- A mechanical gripper squeezes the object with two or more fingers.
- A vacuum gripper sucks the air out from under a suction cup, and the object "sticks".
- Soft silicone grippers wrap around the object, adapting to its shape.
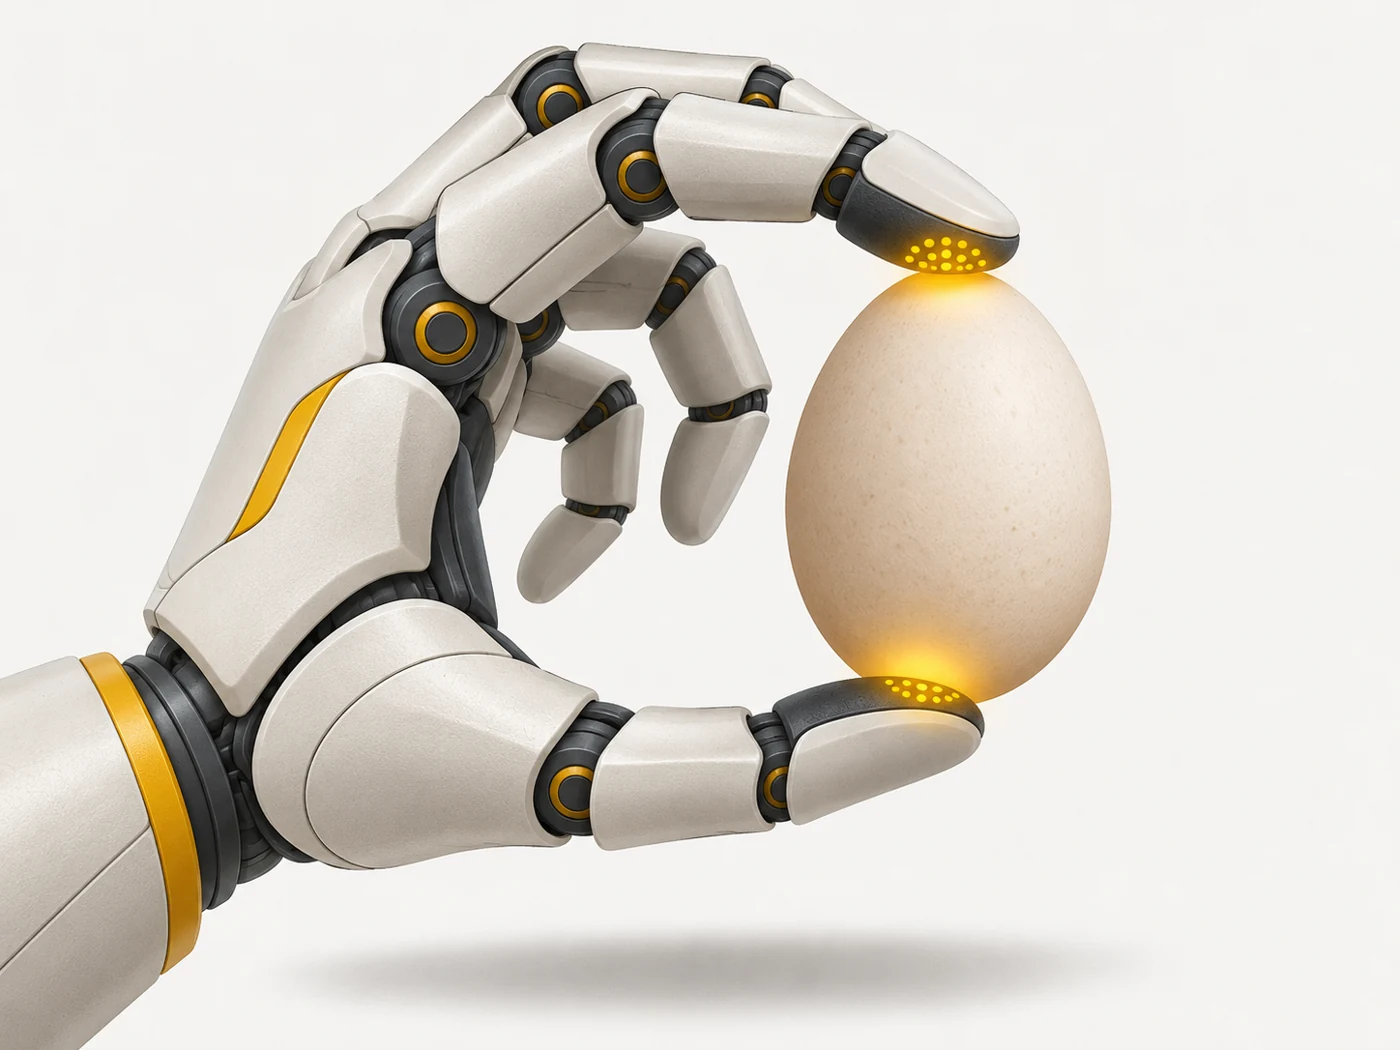
- Force or tactile sensors help it avoid crushing or dropping the object.
Where you'll see it
Warehouses and packaging (suction cups for boxes), the food industry (soft grippers for fruit and baked goods), electronics assembly (tiny fingers), humanoid robots (five-fingered hands) and robot baristas.
Does it matter when buying
For an ordinary user, it is just an interesting fact. But it explains why home helper robots are still rare: picking up any random item in a messy room is one of the hardest problems in robotics. So a video of a robot neatly folding laundry is a serious achievement.
Myths
- Myth: A robot can easily pick up anything, like a human. Reality: Grasping new, soft or slippery objects is still a hard problem.
- Myth: A five-fingered gripper is the best. Reality: For a specific task, a simple suction cup is often more reliable and cheaper.
FAQ
What is an end effector?
The general name for the tool at the end of a robot's arm - a gripper, torch or brush.
How does a robot know how hard to squeeze?
From force and tactile sensors, plus data about the object.
Are there grippers with a sense of touch?
Yes, experimental models have a "skin" with tactile sensors.
Related terms
Robotic arm, Tactile sensor, Collaborative robot (cobot), Humanoid robot