
ROS: the software foundation for robots
ROS (Robot Operating System) is an open-source software framework for building robots: a set of libraries, tools and conventions that helps the different parts of a robot "talk" to each other. Despite the name, it is not an operating system in the usual sense.
In plain words
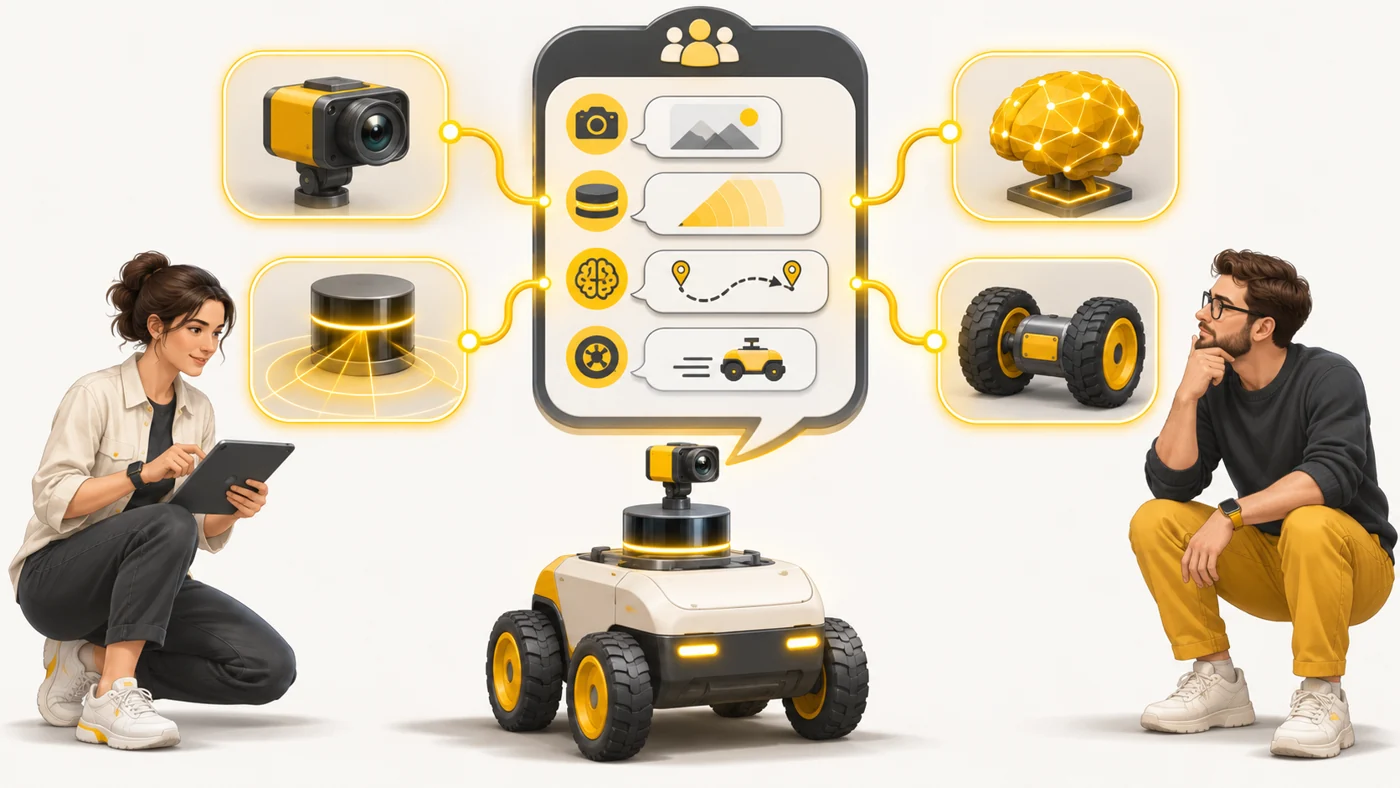
Imagine every sensor and motor in a robot speaks its own language, and they need to cooperate. ROS is like a class group chat where everyone writes by shared rules: the camera posts "I see a wall", navigation reads it and replies "turning left", and the motors do it. Nobody needs to know how the others work - they just read the chat.
How it works
- A robot is made of separate programs called "nodes": camera, lidar, route planner, motor control.
- Nodes exchange messages through "topics" - like channels in a messenger.
- ROS provides ready-made libraries: navigation, SLAM, robotic arm kinematics, visualisation.
- It runs on top of a regular OS, most often Linux.
- The current version is ROS 2, which is more reliable and better suited to real products.
Where you'll see it
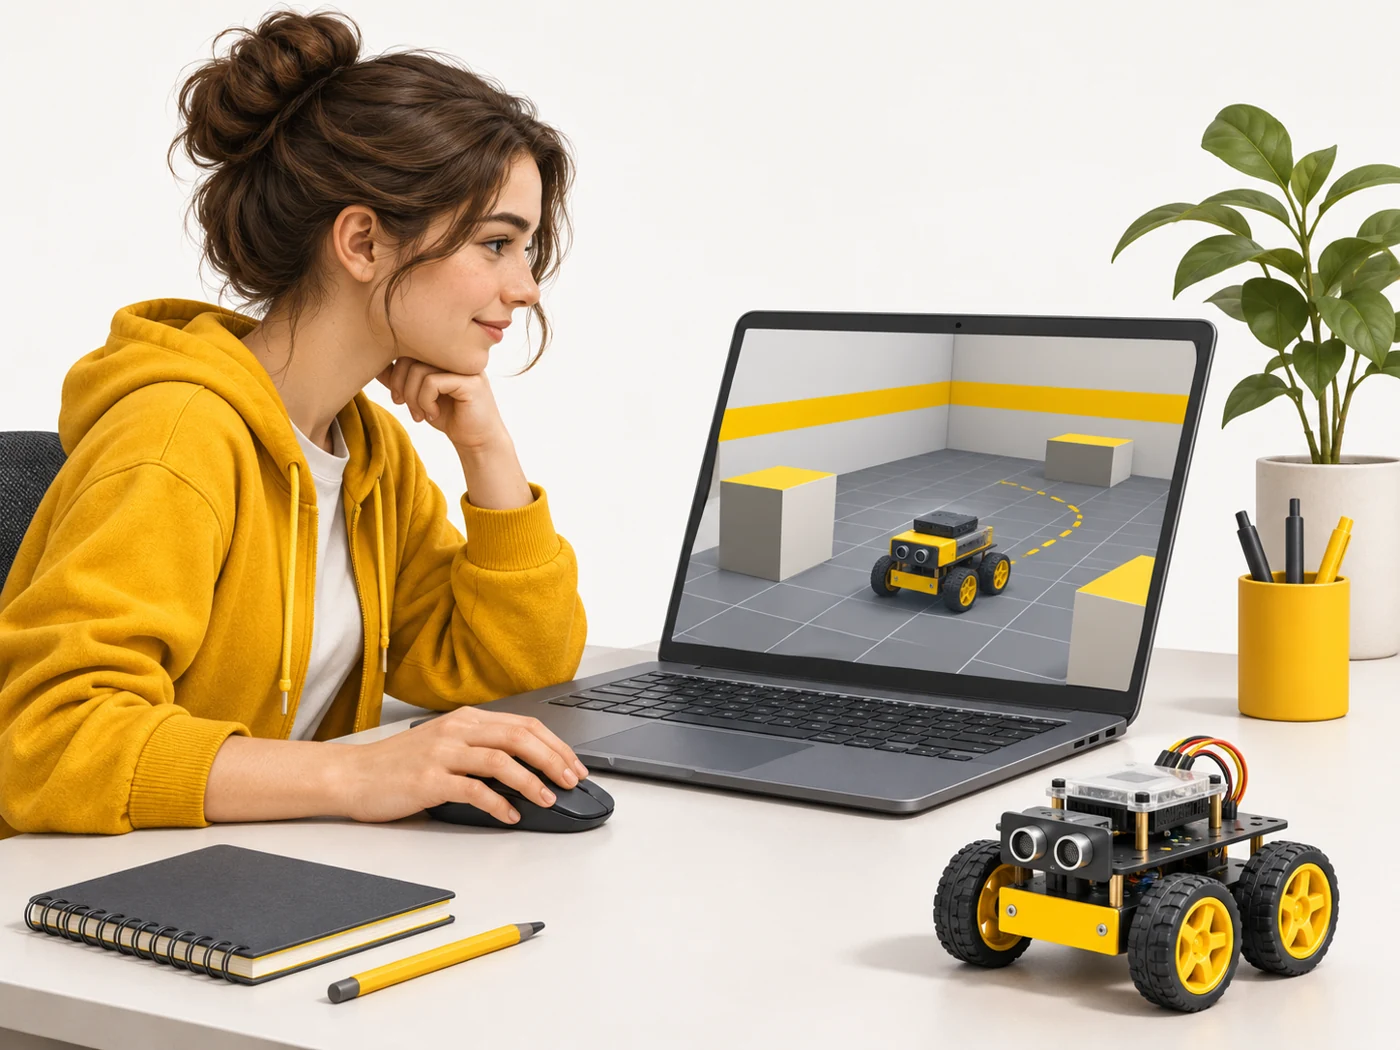
University and educational robots, startups, warehouse and farming robots, research humanoids and autonomous carts. Many robot simulators also work with ROS.
Does it matter when buying
If you want to get serious about robotics after your first Arduino, ROS 2 is the next step. It is free, has a big community and thousands of ready-made packages. To start, you need a computer with Linux and basic Python or C++.
Myths
- Myth: ROS is an operating system like Windows. Reality: It is a set of programs and conventions that runs on top of a real OS.
- Myth: ROS is only for big robots. Reality: It is also used on small educational robots with single-board computers.
FAQ
How is ROS 2 different from ROS 1?
ROS 2 is more reliable and works better with multiple robots and in real time. New projects use ROS 2.
Can I learn ROS without a robot?
Yes, in simulators you can control a virtual robot.
Which language should I learn for ROS?
Python to get started, C++ for performance.